DIN, NUSRAT (2026) Design and Development of Cyber Fish for Investigating and Discovering Underwater Environment = Design and Development of Cyber Fish for Investigating and Discovering Underwater Environment. Thesis thesis, UNIVERSITAS HASANUDDIN.
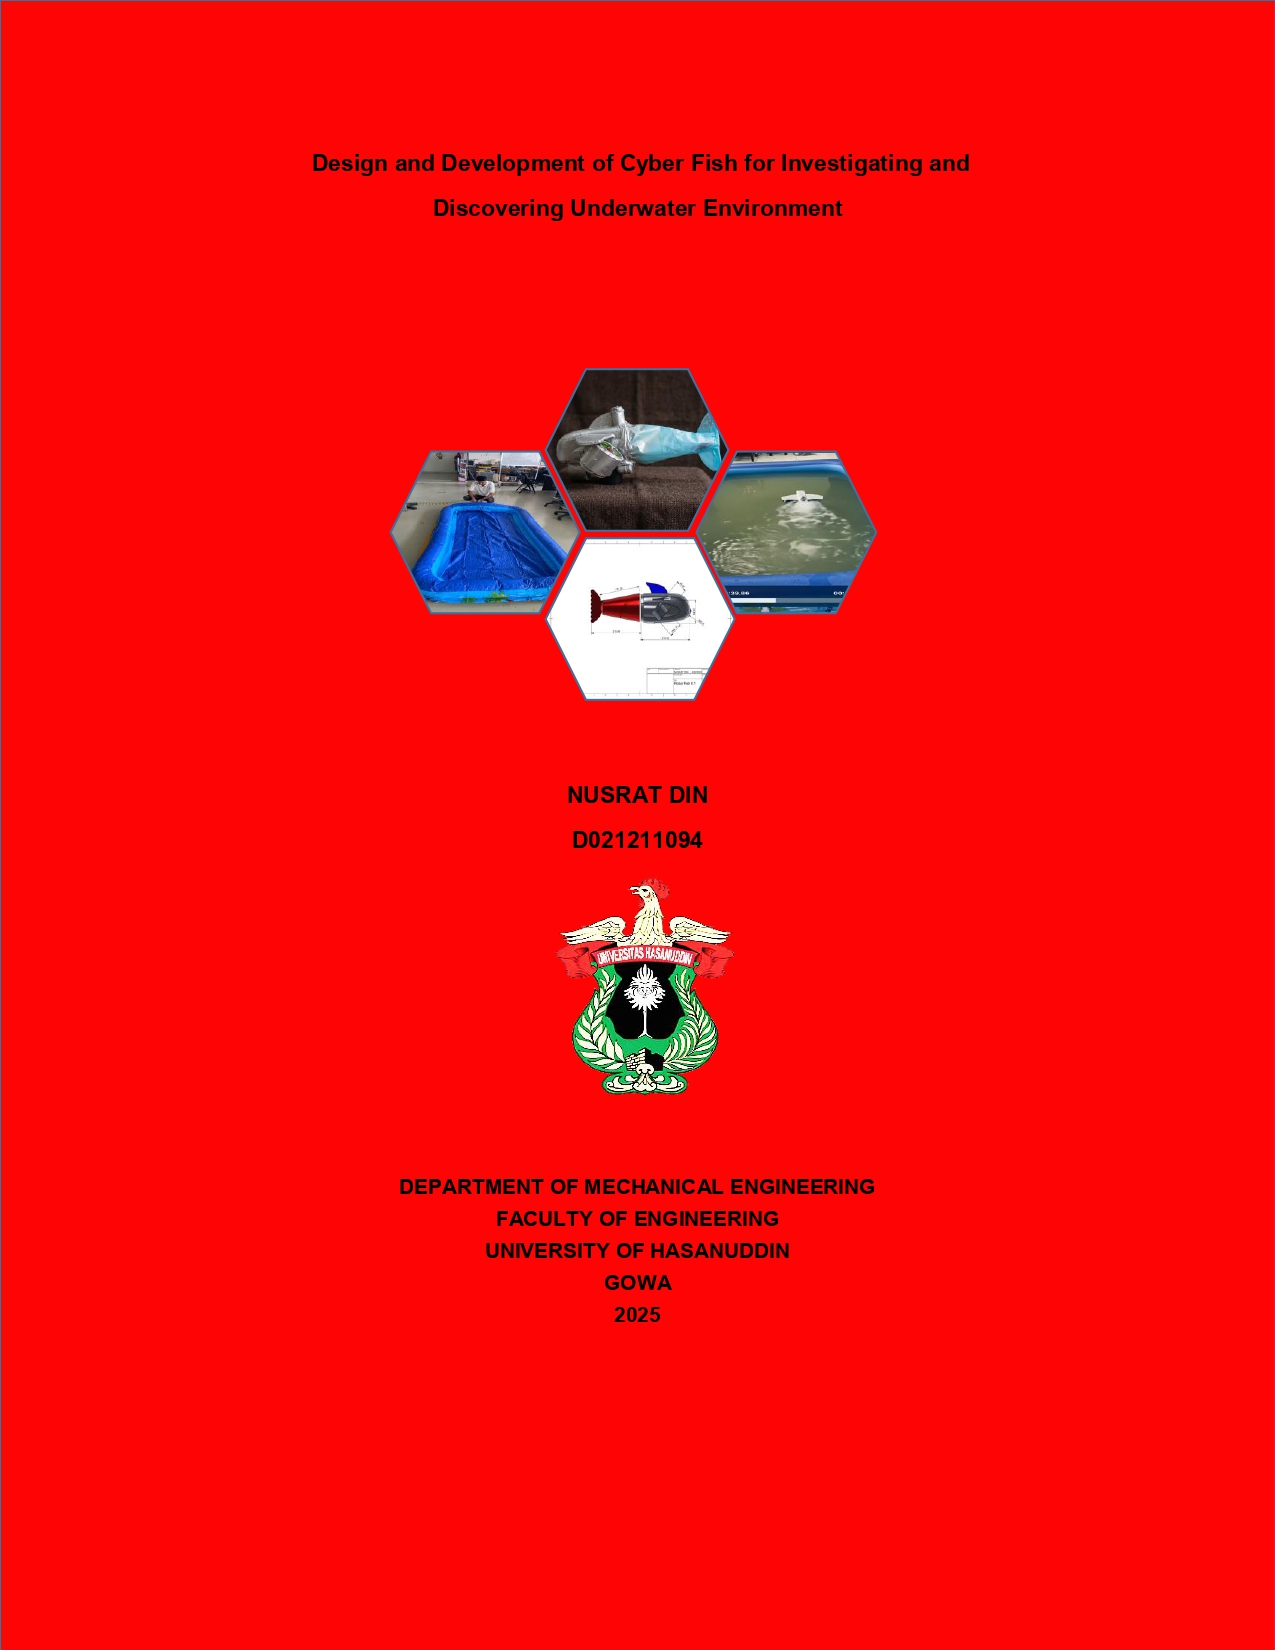 Image (Cover)
D021211094-wAIhVmLlPcK79SBo-20260603090453.jpg
Download (282kB)
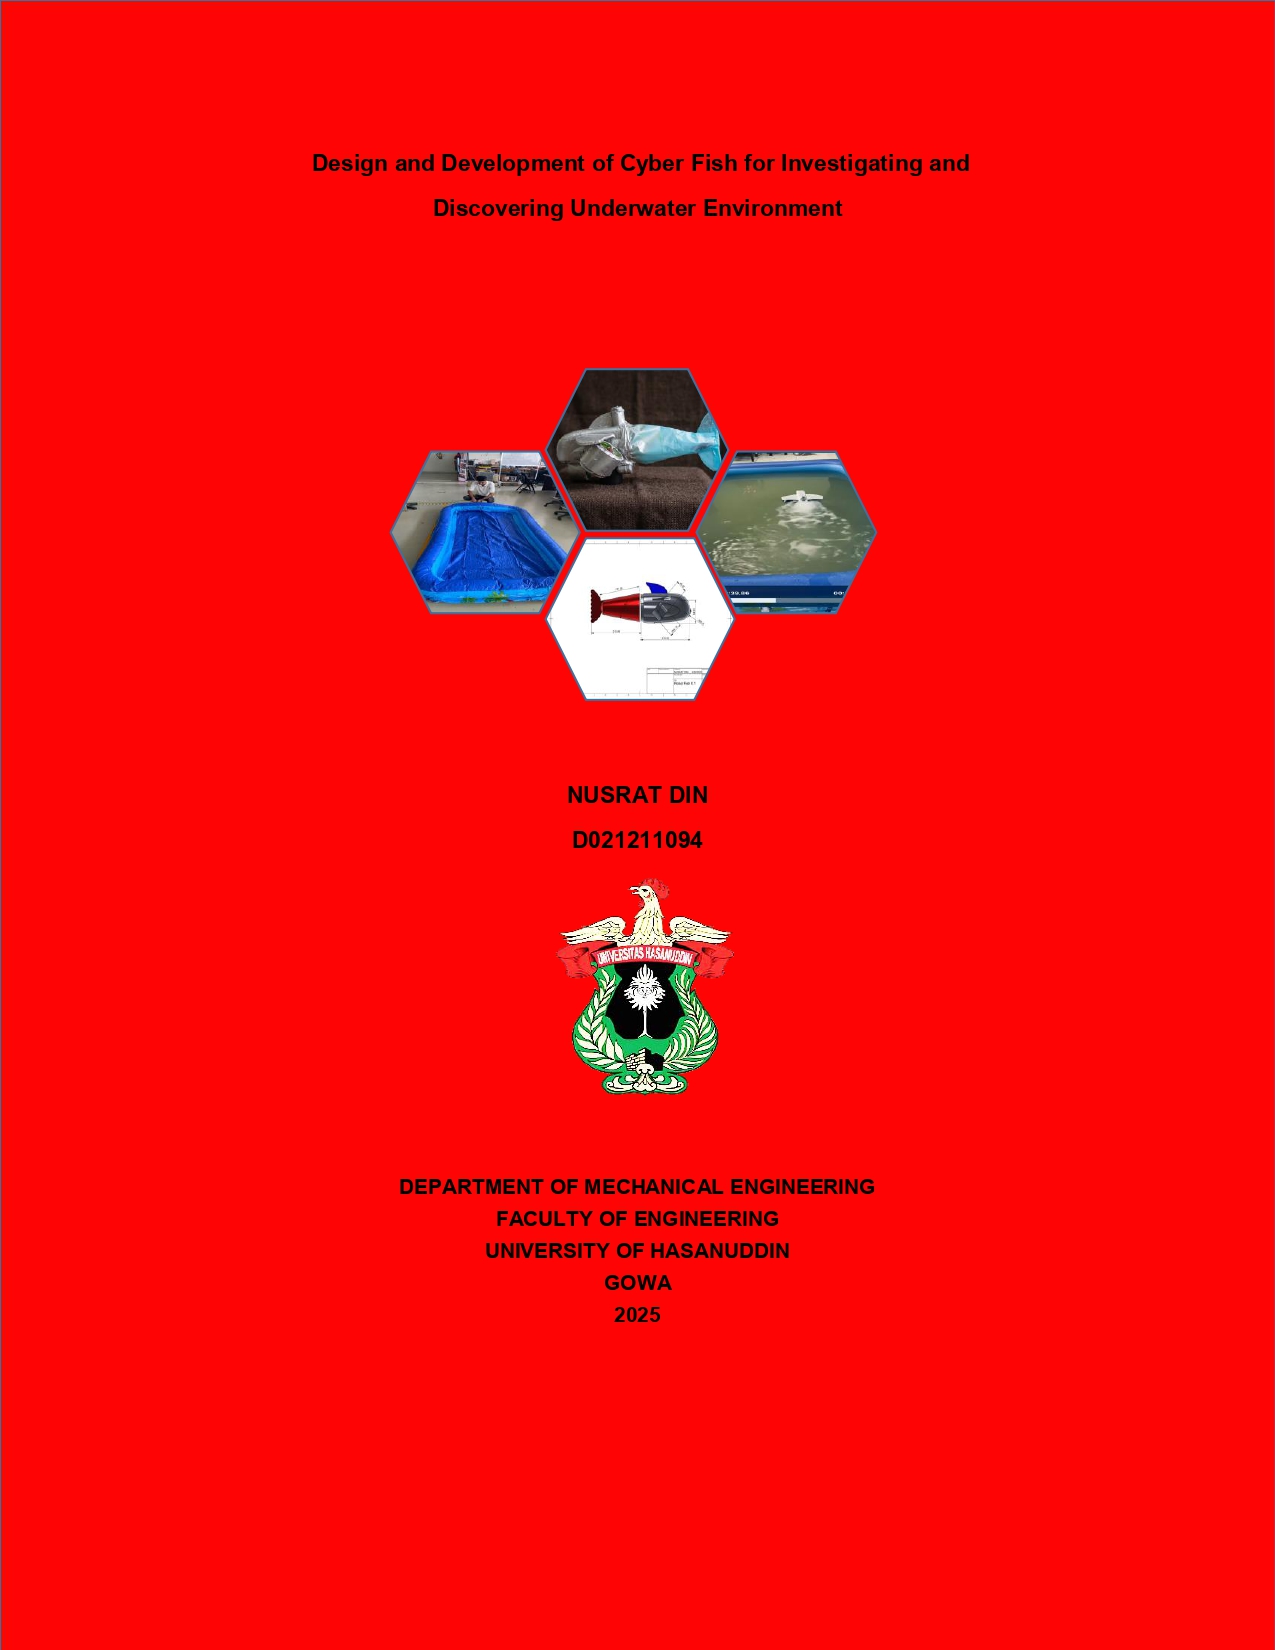
 Text (Bab 1-2)
D021211094-1-2.pdf
Download (2MB)
Text (Dapus)
D021211094-dp.pdf
Download (133kB)
Text (Full Teks)
D021211094-fullllll.pdf
Restricted to Repository staff only until 1 October 2028.
Download (7MB)
Abstract (Abstrak)
NUSRAT DIN. "Design and Development of Cyber Fish for Investigating and Discovering Underwater Environment" Using CFD and Experimental Validation (Supervised by Dr. Eng. Ir. Andi Amijoyo Mochtar, ST., M.Sc.). Background Underwater robots are widely used for inspection exploration and monitoring in underwater environments. Understanding the hydrodynamic behavior of a robot moving in water is important to improve its stability and efficiency. Therefore both simulation and experimental testing are required to evaluate the robot’s performance. Objective The objective of this study design and develop an underwater robot to analyze the motion and hydrodynamic performance of the underwater robot. Another objective is to compare the simulation results with the experimental observations in order to validate the robot design and its operational stability in water. Method in this research a CFD simulation was conducted to observe velocity distribution, pressure effects, and turbulence around the robot body. The simulation model was created and analyzed under a defined inlet velocity condition. After simulation, a practical experiment was performed in a water tank to observe the actual movement and behavior of the robot. Result the simulation results show that the water flow interacts with the robot body and forms a stable flow pattern along its surface. A small turbulence region was observed around the robot. The experimental results also indicate that the robot can move forward smoothly and maintain stable motion in water. Conclusion Based on the simulation and experimental analysis the underwater robot stable stable hydrodynamic performance the results confirm that the robot design is capable of operating efficiently in water with minimal turbulence and acceptable flow behavior. Keywords: Automatic Cyber Fish, Underwater robot, Autonomous Underwater Vehicle, Bio inspired robot Design and developed underwater robot.
| Item Type: | Thesis (Thesis) |
|---|---|
| Uncontrolled Keywords: | Keywords: Automatic Cyber Fish, Underwater robot, Autonomous Underwater Vehicle, Bio inspired robot Design and developed underwater robot. |
| Subjects: | T Technology > TA Engineering (General). Civil engineering (General) |
| Divisions (Program Studi): | Fakultas Teknik > Teknik Mesin |
| Depositing User: | - Andi Anna |
| Date Deposited: | 01 Oct 2026 07:35 |
| Last Modified: | 01 Oct 2026 07:35 |
| URI: | http://repository.unhas.ac.id:443/id/eprint/58680 |
Actions (login required)

- View Item